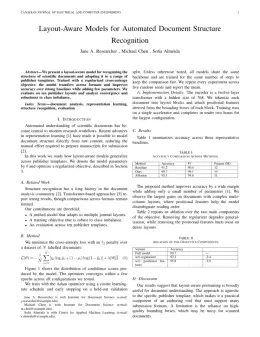
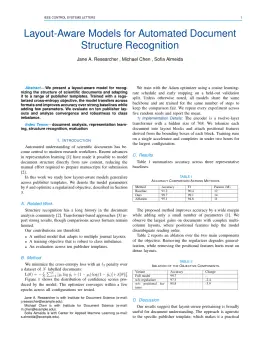
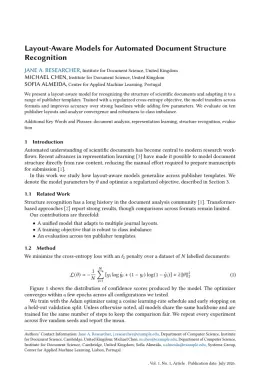
About the IEEE Robotics & Automation Magazine format
IEEE Robotics & Automation Magazine is a peer-reviewed journal published by IEEE, covering Robotics and Automated Systems, Modular Robots and Swarm Intelligence, Robot Manipulation and Learning. Over its lifetime it has published 3,042 papers, which have received 88,319 citations.
| Publisher | IEEE |
|---|
| Reference style | Numbered (IEEE) Numbered — [1], [2] in the text
[1] A. Smith, B. Jones, and C. Lee, "A representative article title," IEEE Robotics & Automation Magazine, vol. 12, no. 3, pp. 45–58, 2023.
Formats any DOI in IEEE Robotics & Automation Magazine style. No sign-up.
|
|---|
| Abbreviation (ISO-4) | R&AM |
|---|
| Publishes research in | Robotics and Automated Systems Modular Robots and Swarm Intelligence Robot Manipulation and Learning Robotic Path Planning Algorithms Advanced Manufacturing and Logistics Optimization |
|---|
| ISSN | 1070-9932 |
|---|
| Citation impact (2-yr) | 1.7 |
|---|
| h-index | 127 |
|---|
| i10-index | 904 |
|---|
| Top institutions publishing here | Italian Institute of Technology |
|---|
| You get | A submission-ready PDF and the editable LaTeX source — ready to submit. |
|---|
Papers published in IEEE Robotics & Automation Magazine per year
Citation impact of IEEE Robotics & Automation Magazine by publication year
Citations each year’s papers have accumulated so far — the most recent years are still building up.
Most-cited papers in IEEE Robotics & Automation Magazine
Simultaneous localization and mapping: part I
Hugh Durrant‐Whyte, T. Bailey · 1 Jun 2006
This paper describes the simultaneous localization and mapping (SLAM) problem and the essential methods for solving the SLAM problem and summarizes key implementations and demonstrations of the method. While there are still many practical issues to overcome, especially in more complex outdoor environments, the general SLAM method is now a well understood and established part…
The dynamic window approach to collision avoidance
D. Fox, Wolfram Burgard, Sebastian Thrun · 1 Mar 1997
This approach, designed for mobile robots equipped with synchro-drives, is derived directly from the motion dynamics of the robot. In experiments, the dynamic window approach safely controlled the mobile robot RHINO at speeds of up to 95 cm/sec, in populated and dynamic environments.
The Uncanny Valley [From the Field]
Masahiro Mori, Karl F. MacDorman, Norri Kageki · 1 Jun 2012
More than 40 years ago, Masahiro Mori, a robotics professor at the Tokyo Institute of Technology, wrote an essay [1] on how he envisioned people's reactions to robots that looked and acted almost like a human. In particular, he hypothesized that a person's response to a humanlike robot would abruptly shift from empathy to revulsion…
Simultaneous localization and mapping (SLAM): part II
T. Bailey, Hugh Durrant‐Whyte · 23 Aug 2006
This paper discusses the recursive Bayesian formulation of the simultaneous localization and mapping (SLAM) problem in which probability distributions or estimates of absolute or relative locations of landmarks and vehicle pose are obtained. The paper focuses on three key areas: computational complexity; data association; and environment representation.
Visual servo control. I. Basic approaches
François Chaumette, Seth Hutchinson · 1 Dec 2006
This paper is the first of a two-part series on the topic of visual servo control using computer vision data in the servo loop to control the motion of a robot. In this paper, we describe the basic techniques that are by now well established in the field. We first give a general overview of…