ACM

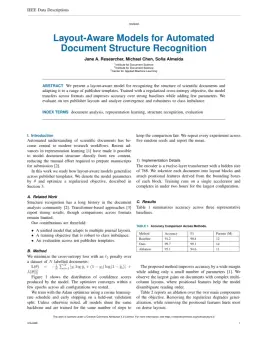
ACM Journal on Autonomous Transportation Systems Template

Write in a clean editor, then format for ACM Journal on Autonomous Transportation Systems in one click — DocuGuru applies the official ACM template with numbered references and exports a submission-ready PDF plus the editable LaTeX source. Free to start.

About the ACM Journal on Autonomous Transportation Systems format

ACM Journal on Autonomous Transportation Systems is a peer-reviewed journal published by ACM, covering Autonomous Vehicle Technology and Safety, Traffic control and management, Vehicular Ad Hoc Networks (VANETs). Over its lifetime it has published 70 papers, which have received 282 citations.

PublisherACM
Reference styleNumbered (ACM)
Numbered — [1], [2] in the text
[1] Ada Smith, Ben Jones, and Cara Lee. 2023. A representative article title. ACM Journal on Autonomous Transportation Systems 12, 3, Article 45 (2023).

Formats any DOI in ACM Journal on Autonomous Transportation Systems style. No sign-up.

Publishes research inAutonomous Vehicle Technology and Safety Traffic control and management Vehicular Ad Hoc Networks (VANETs) UAV Applications and Optimization Advanced Neural Network Applications
ISSN2833-0528
Citation impact (2-yr)3.3
h-index8
i10-index6
Top institutions publishing hereClemson University
You getA submission-ready PDF and the editable LaTeX source — ready to submit.

Papers published in ACM Journal on Autonomous Transportation Systems per year

9
2023
27
2024
25
2025

Citation impact of ACM Journal on Autonomous Transportation Systems by publication year

80
2023
158
2024
32
2025

Citations each year’s papers have accumulated so far — the most recent years are still building up.

Most-cited papers in ACM Journal on Autonomous Transportation Systems

Collaborative Multi-task Learning for Multi-Object Tracking and Segmentation

Yiming Cui, Cheng Han, Dongfang Liu · 10 Nov 2023

The advancement of computer vision has pushed visual analysis tasks from still images to the video domain. In recent years, video instance segmentation, which aims at tracking and segment multiple objects in video frames, has drawn much attention for its potential applications in various emerging areas such as autonomous driving, intelligent transportation, and smart retail.…

Bridging the Domain Gap between Synthetic and Real-World Data for Autonomous Driving

Xiangyu Bai, Yedi Luo, Le Jiang et al. · 23 Nov 2023

Modern autonomous systems require extensive testing to ensure reliability and build trust in ground vehicles. However, testing these systems in the real-world is challenging due to the lack of large and diverse datasets, especially in edge cases. Therefore, simulations are necessary for their development and evaluation. However, existing open-source simulators often exhibit a significant gap…

CAV Traffic Control to Mitigate the Impact of Congestion from Bottlenecks: A Linear Quadratic Regulator Approach and Microsimulation Study

Suyash C. Vishnoi, Junyi Ji, MirSaleh Bahavarnia et al. · 9 Dec 2023

This work investigates traffic control via controlled connected and autonomous vehicles (CAVs) using novel controllers derived from the linear-quadratic regulator (LQR) theory. CAV-platoons are modeled as moving bottlenecks impacting the surrounding traffic with their speeds as control inputs. An iterative controller algorithm based on the LQR theory is proposed along with a variant that allows…

Secure Aggregation for Privacy-preserving Federated Learning in Vehicular Networks

SangHyun Byun, Arijet Sarker, Sang‐Yoon Chang et al. · 13 Apr 2024

The automotive industry has been enhancing autonomous driving systems utilizing the computation and communication networks embedded in vehicles (e.g., cellular networks and sensors) and roadside units (e.g., radar and cameras). Robust security and privacy requirements are essential in Intelligent Transportation Systems (ITSs). To satisfy these requirements, most developed autonomous driving systems (e.g., Waymo and Tesla)…

Car-Following-Response-Based Vehicle Classification via Deep Learning

Tianyi Li, Raphael Stern · 10 Jun 2023

The driving characteristics of individual vehicles in the flow have been shown to influence the aggregate traffic flow characteristics. This is true both for individual human drivers as well as vehicles with some level of automation, such as adaptive cruise control (ACC). Knowledge of the individual constituents of the traffic flow will allow for more…

ACM Journal on Autonomous Transportation Systems template — frequently asked questions

How do I write a paper in the ACM Journal on Autonomous Transportation Systems format?
In DocuGuru you write your manuscript in a normal editor — no LaTeX setup required — and select the ACM Journal on Autonomous Transportation Systems template. When you export, DocuGuru compiles the paper into the official ACM format and hands you a submission-ready PDF along with the editable LaTeX source.
What reference style does ACM Journal on Autonomous Transportation Systems use?
ACM Journal on Autonomous Transportation Systems uses Numbered (ACM) references, shown as numbered [1], [2] markers in the text. DocuGuru formats every in-text citation and the reference list in this exact style automatically. A reference appears like this: [1] Ada Smith, Ben Jones, and Cara Lee. 2023. A representative article title. ACM Journal on Autonomous Transportation Systems 12, 3, Article 45 (2023).
Do I need to know LaTeX to submit to ACM Journal on Autonomous Transportation Systems?
No. DocuGuru generates the acmart LaTeX class and compiles the PDF for you in the background, so you get a ACM-ready ACM Journal on Autonomous Transportation Systems document without writing any LaTeX. If you do want it, the LaTeX source is included in the export.
Can I import an existing draft into the ACM Journal on Autonomous Transportation Systems template?
Yes. Paste or upload your current manuscript — Word, LaTeX, Markdown, or plain text — and DocuGuru reflows it into the ACM Journal on Autonomous Transportation Systems format with correct headings, figures, tables, and numbered citations.
What is ACM Journal on Autonomous Transportation Systems?
ACM journal. It is a engineering and computer science journal, published by ACM.
Can I export a submission-ready ACM Journal on Autonomous Transportation Systems PDF?
Yes — DocuGuru produces a PDF built with the official ACM Journal on Autonomous Transportation Systems template (the acmart class) that is ready to submit to ACM, together with the matching LaTeX source files.
How much does the ACM Journal on Autonomous Transportation Systems template cost?
You can start writing in the ACM Journal on Autonomous Transportation Systems template for free. Exporting the final submission-ready ACM Journal on Autonomous Transportation Systems PDF and LaTeX source is part of DocuGuru's paid plans — see the app for current pricing.
Use the ACM Journal on Autonomous Transportation Systems template