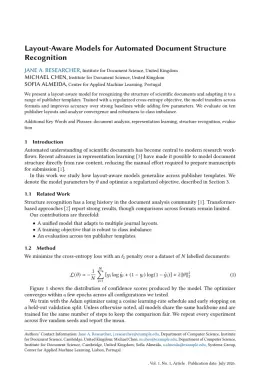
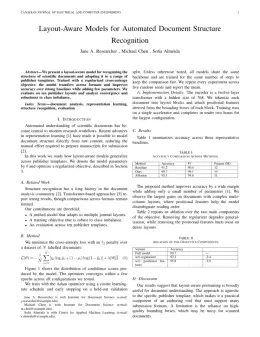
About the ACM Transactions on Human-Robot Interaction format
ACM Transactions on Human-Robot Interaction is a peer-reviewed journal published by ACM, covering Social Robot Interaction and HRI, Human-Automation Interaction and Safety, AI in Service Interactions. Over its lifetime it has published 463 papers, which have received 8,346 citations.
| Publisher | ACM |
|---|
| Reference style | Numbered (ACM) Numbered — [1], [2] in the text
[1] Ada Smith, Ben Jones, and Cara Lee. 2023. A representative article title. ACM Transactions on Human-Robot Interaction 12, 3, Article 45 (2023).
Formats any DOI in ACM Transactions on Human-Robot Interaction style. No sign-up.
|
|---|
| Publishes research in | Social Robot Interaction and HRI Human-Automation Interaction and Safety AI in Service Interactions Robot Manipulation and Learning Ethics and Social Impacts of AI |
|---|
| ISSN | 2573-9522 |
|---|
| Citation impact (2-yr) | 5.45 |
|---|
| h-index | 46 |
|---|
| i10-index | 206 |
|---|
| Top institutions publishing here | Kyoto University |
|---|
| Journal website | thri.acm.org |
|---|
| You get | A submission-ready PDF and the editable LaTeX source — ready to submit. |
|---|
Papers published in ACM Transactions on Human-Robot Interaction per year
Citation impact of ACM Transactions on Human-Robot Interaction by publication year
Citations each year’s papers have accumulated so far — the most recent years are still building up.
Most-cited papers in ACM Transactions on Human-Robot Interaction
Core Challenges of Social Robot Navigation: A Survey
Christoforos Mavrogiannis, Francesca Baldini, Allan Wang et al. · 17 Feb 2023
Robot navigation in crowded public spaces is a complex task that requires addressing a variety of engineering and human factors challenges. These challenges have motivated a great amount of research resulting in important developments for the fields of robotics and human-robot interaction over the past three decades. Despite the significant progress and the massive recent…
Robots in the Wild
Malte Jung, Pamela Hinds · 21 May 2018
Human-robot interaction (HRI) research to date has been dominated by laboratory studies, largely examining a single human interacting with a single robot. This research has helped establish a fundamental understanding about people as they interact with robots, how specific design choices affect interactions with robots, and how novel mechanisms or computational tools can be used…
Trust-Aware Decision Making for Human-Robot Collaboration
Min Chen, Stefanos Nikolaidis, Harold Soh et al. · 30 Jan 2020
Trust in autonomy is essential for effective human-robot collaboration and user adoption of autonomous systems such as robot assistants. This article introduces a computational model that integrates trust into robot decision making. Specifically, we learn from data a partially observable Markov decision process (POMDP) with human trust as a latent variable. The trust-POMDP model provides…
A Survey of Robot-Assisted Language Learning (RALL)
Natasha Randall · 11 Dec 2019
Robot-assisted language learning (RALL) is becoming a more commonly studied area of human-robot interaction (HRI). This research draws on theories and methods from many different fields, with researchers utilizing different instructional methods, robots, and populations to evaluate the effectiveness of RALL. This survey details the characteristics of robots used—form, voice, immediacy, non-verbal cues, and personalization—along…
Friend or Foe? Understanding Assembly Workers’ Acceptance of Human-robot Collaboration
Antonia Meißner, Angelika Trübswetter, Antonia S. Conti-Kufner et al. · 14 Jul 2020
Due to rising demands on productivity and flexibility, assembly processes are currently experiencing a substantial transformation. Workstations where humans and robots work closely together are becoming increasingly popular, as they provide major advantages compared to manual assembly and full automation. Yet, human-robot collaboration (HRC) can only be successful if the workforce is willing to accept…