How do I write a paper in the IEEE Transactions on Field Robotics format?
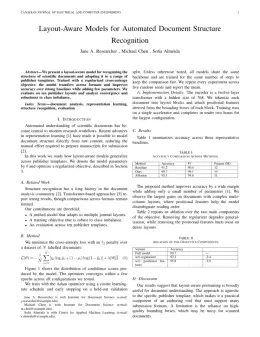
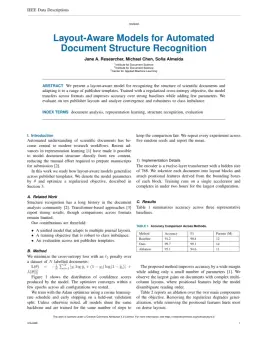
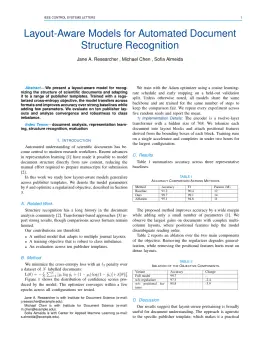
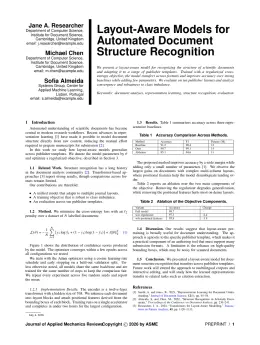
In DocuGuru you write your manuscript in a normal editor — no LaTeX setup required — and select the IEEE Transactions on Field Robotics template. When you export, DocuGuru compiles the paper into the official IEEE format and hands you a submission-ready PDF along with the editable LaTeX source.
What reference style does IEEE Transactions on Field Robotics use?
IEEE Transactions on Field Robotics uses Numbered (IEEE) references, shown as numbered [1], [2] markers in the text. DocuGuru formats every in-text citation and the reference list in this exact style automatically. A reference appears like this: [1] A. Smith, B. Jones, and C. Lee, "A representative article title," IEEE Transactions on Field Robotics, vol. 12, no. 3, pp. 45–58, 2023.
Do I need to know LaTeX to submit to IEEE Transactions on Field Robotics?
No. DocuGuru generates the ieeetj LaTeX class and compiles the PDF for you in the background, so you get a IEEE-ready IEEE Transactions on Field Robotics document without writing any LaTeX. If you do want it, the LaTeX source is included in the export.
Can I import an existing draft into the IEEE Transactions on Field Robotics template?
Yes. Paste or upload your current manuscript — Word, LaTeX, Markdown, or plain text — and DocuGuru reflows it into the IEEE Transactions on Field Robotics format with correct headings, figures, tables, and numbered citations.
What is IEEE Transactions on Field Robotics?
IEEE Transactions on Field Robotics, published by IEEE. It is a engineering and computer science journal, published by IEEE.
Can I export a submission-ready IEEE Transactions on Field Robotics PDF?
Yes — DocuGuru produces a PDF built with the official IEEE Transactions on Field Robotics template (the ieeetj class) that is ready to submit to IEEE, together with the matching LaTeX source files.
How much does the IEEE Transactions on Field Robotics template cost?
You can start writing in the IEEE Transactions on Field Robotics template for free. Exporting the final submission-ready IEEE Transactions on Field Robotics PDF and LaTeX source is part of DocuGuru's paid plans — see the app for current pricing.