IEEE

IEEE Transactions on Robotics Template

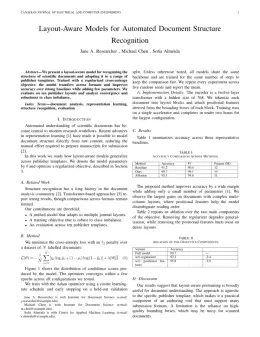
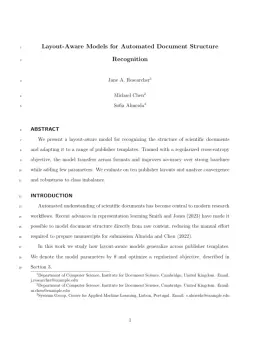
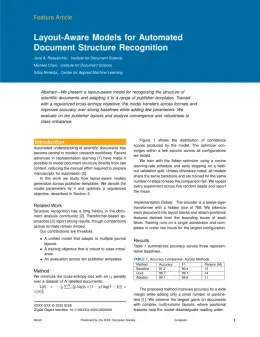
Write in a clean editor, then format for IEEE Transactions on Robotics in one click — DocuGuru applies the official IEEE template with numbered references and exports a submission-ready PDF plus the editable LaTeX source. Free to start.

About the IEEE Transactions on Robotics format

IEEE Transactions on Robotics is a peer-reviewed journal published by IEEE, covering Robot Manipulation and Learning, Robotic Path Planning Algorithms, Soft Robotics and Applications. Over its lifetime it has published 4,181 papers, which have received 274,950 citations.

PublisherIEEE
Reference styleNumbered (IEEE)
Numbered — [1], [2] in the text
[1] A. Smith, B. Jones, and C. Lee, "A representative article title," IEEE Transactions on Robotics, vol. 12, no. 3, pp. 45–58, 2023.

Formats any DOI in IEEE Transactions on Robotics style. No sign-up.

Abbreviation (ISO-4)TRO
Publishes research inRobot Manipulation and Learning Robotic Path Planning Algorithms Soft Robotics and Applications Robotics and Sensor-Based Localization Robotic Mechanisms and Dynamics
ISSN1552-3098
Citation impact (2-yr)7.8
h-index227
i10-index2,691
Top institutions publishing hereCentre National de la Recherche Scientifique
Journal websiteieeexplore.ieee.org
You getA submission-ready PDF and the editable LaTeX source — ready to submit.

Papers published in IEEE Transactions on Robotics per year

149
2014
160
2015
177
2016
151
2017
163
2018
155
2019
181
2020
238
2021
237
2022
301
2023
264
2024
351
2025

Citation impact of IEEE Transactions on Robotics by publication year

9.2K
2014
20.2K
2015
15.5K
2016
15K
2017
13.3K
2018
6.9K
2019
8K
2020
12.9K
2021
10.5K
2022
9K
2023
4K
2024
1.5K
2025

Citations each year’s papers have accumulated so far — the most recent years are still building up.

Most-cited papers in IEEE Transactions on Robotics

ORB-SLAM: A Versatile and Accurate Monocular SLAM System

Raul Mur-Artal, J. M. M. Montiel, Juan D. Tardos · 24 Aug 2015

This paper presents ORB-SLAM, a feature-based monocular simultaneous localization and mapping (SLAM) system that operates in real time, in small and large indoor and outdoor environments. The system is robust to severe motion clutter, allows wide baseline loop closing and relocalization, and includes full automatic initialization. Building on excellent algorithms of recent years, we designed…

6,514 citations Cite SaveGo to paper →
ORB-SLAM2: An Open-Source SLAM System for Monocular, Stereo, and RGB-D Cameras

Raul Mur-Artal, Juan D. Tardos · 12 Jun 2017

We present ORB-SLAM2, a complete simultaneous localization and mapping (SLAM) system for monocular, stereo and RGB-D cameras, including map reuse, loop closing, and relocalization capabilities. The system works in real time on standard central processing units in a wide variety of environments from small hand-held indoors sequences, to drones flying in industrial environments and cars…

6,051 citations Cite SaveGo to paper →
VINS-Mono: A Robust and Versatile Monocular Visual-Inertial State Estimator

Tong Qin, Peiliang Li, Shaojie Shen · 27 Jul 2018

One camera and one low-cost inertial measurement unit (IMU) form a monocular visual-inertial system (VINS), which is the minimum sensor suite (in size, weight, and power) for the metric six degrees-of-freedom (DOF) state estimation. In this paper, we present VINS-Mono: a robust and versatile monocular visual-inertial state estimator. Our approach starts with a robust procedure…

4,472 citations Cite SaveGo to paper →
ORB-SLAM3: An Accurate Open-Source Library for Visual, Visual–Inertial, and Multimap SLAM

Carlos Campos, Richard Elvira, Juan J. Gomez Rodriguez et al. · 25 May 2021

This article presents ORB-SLAM3, the first system able to perform visual, visual-inertial and multimap SLAM with monocular, stereo and RGB-D cameras, using pin-hole and fisheye lens models. The first main novelty is a tightly integrated visual-inertial SLAM system that fully relies on maximum <italic xmlns:mml="http://www.w3.org/1998/Math/MathML" xmlns:xlink="http://www.w3.org/1999/xlink">a posteriori</i> (MAP) estimation, even during IMU initialization, resulting in…

3,902 citations Cite SaveGo to paper →
Past, Present, and Future of Simultaneous Localization and Mapping: Toward the Robust-Perception Age

Cesar Cadena, Luca Carlone, Henry Carrillo et al. · 1 Dec 2016

Simultaneous localization and mapping (SLAM) consists in the concurrent construction of a model of the environment (the map), and the estimation of the state of the robot moving within it. The SLAM community has made astonishing progress over the last 30 years, enabling large-scale real-world applications and witnessing a steady transition of this technology to…

3,325 citations Cite SaveGo to paper →

IEEE Transactions on Robotics template — frequently asked questions

How do I write a paper in the IEEE Transactions on Robotics format?
In DocuGuru you write your manuscript in a normal editor — no LaTeX setup required — and select the IEEE Transactions on Robotics template. When you export, DocuGuru compiles the paper into the official IEEE format and hands you a submission-ready PDF along with the editable LaTeX source.
What reference style does IEEE Transactions on Robotics use?
IEEE Transactions on Robotics uses Numbered (IEEE) references, shown as numbered [1], [2] markers in the text. DocuGuru formats every in-text citation and the reference list in this exact style automatically. A reference appears like this: [1] A. Smith, B. Jones, and C. Lee, "A representative article title," IEEE Transactions on Robotics, vol. 12, no. 3, pp. 45–58, 2023.
Do I need to know LaTeX to submit to IEEE Transactions on Robotics?
No. DocuGuru generates the IEEEtran LaTeX class and compiles the PDF for you in the background, so you get a IEEE-ready IEEE Transactions on Robotics document without writing any LaTeX. If you do want it, the LaTeX source is included in the export.
Can I import an existing draft into the IEEE Transactions on Robotics template?
Yes. Paste or upload your current manuscript — Word, LaTeX, Markdown, or plain text — and DocuGuru reflows it into the IEEE Transactions on Robotics format with correct headings, figures, tables, and numbered citations.
Who publishes IEEE Transactions on Robotics?
IEEE Transactions on Robotics is a engineering and computer science journal published by IEEE. DocuGuru's IEEE Transactions on Robotics template matches IEEE's official submission format.
Can I export a submission-ready IEEE Transactions on Robotics PDF?
Yes — DocuGuru produces a PDF built with the official IEEE Transactions on Robotics template (the IEEEtran class) that is ready to submit to IEEE, together with the matching LaTeX source files.
How much does the IEEE Transactions on Robotics template cost?
You can start writing in the IEEE Transactions on Robotics template for free. Exporting the final submission-ready IEEE Transactions on Robotics PDF and LaTeX source is part of DocuGuru's paid plans — see the app for current pricing.
Use the IEEE Transactions on Robotics template