IEEE

IEEE Open Journal of Control Systems Template

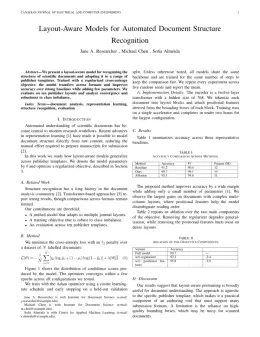
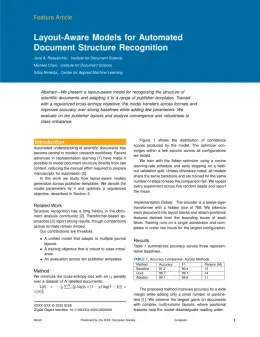
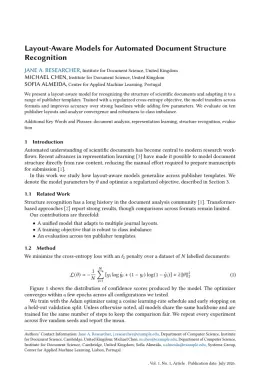
Write in a clean editor, then format for IEEE Open Journal of Control Systems in one click — DocuGuru applies the official IEEE template with numbered references and exports a submission-ready PDF plus the editable LaTeX source. Free to start.

About the IEEE Open Journal of Control Systems format

IEEE Open Journal of Control Systems is a peer-reviewed journal published by IEEE, covering Advanced Control Systems Optimization, Control Systems and Identification, Reinforcement Learning in Robotics. Over its lifetime it has published 190 papers, which have received 654 citations.

PublisherIEEE
Reference styleNumbered (IEEE)
Numbered — [1], [2] in the text
[1] A. Smith, B. Jones, and C. Lee, "A representative article title," IEEE Open Journal of Control Systems, vol. 12, no. 3, pp. 45–58, 2023.

Formats any DOI in IEEE Open Journal of Control Systems style. No sign-up.

Publishes research inAdvanced Control Systems Optimization Control Systems and Identification Reinforcement Learning in Robotics Fault Detection and Control Systems Smart Grid Security and Resilience
ISSN2694-085X
Citation impact (2-yr)1.27
h-index14
i10-index24
Open accessYes — indexed in DOAJ
Top institutions publishing hereUniversity of California San Diego
You getA submission-ready PDF and the editable LaTeX source — ready to submit.

Papers published in IEEE Open Journal of Control Systems per year

35
2022
42
2023
38
2024
48
2025

Citation impact of IEEE Open Journal of Control Systems by publication year

272
2022
228
2023
95
2024
34
2025

Citations each year’s papers have accumulated so far — the most recent years are still building up.

Most-cited papers in IEEE Open Journal of Control Systems

Provably Safe Reinforcement Learning via Action Projection Using Reachability Analysis and Polynomial Zonotopes

Niklas Kochdumper, Hanna Krasowski, Xiao Wang et al. · 1 Jan 2023

While reinforcement learning produces very promising results for many applications, its main disadvantage is the lack of safety guarantees, which prevents its use in safety-critical systems. In this work, we address this issue by a safety shield for nonlinear continuous systems that solve reach-avoid tasks. Our safety shield prevents applying potentially unsafe actions from a…

Distributed Anytime-Feasible Resource Allocation Subject to Heterogeneous Time-Varying Delays

Mohammadreza Doostmohammadian, Alireza Aghasi, Apostolos I. Rikos et al. · 1 Jan 2022

This paper considers distributed allocation strategies, formulated as a distributed sum-preserving (fixed-sum) allocation of resources over a multi-agent network in the presence of heterogeneous arbitrary time-varying delays. We propose a double time-scale scenario for unknown delays and a faster single time-scale scenario for known delays. Further, the links among the nodes are considered subject to…

Optimally Biomimetic Passivity-Based Control of a Lower-Limb Exoskeleton Over the Primary Activities of Daily Life

Jianping Lin, Nikhil Divekar, Gray C. Thomas et al. · 1 Jan 2022

Task-specific, trajectory-based control methods commonly used in exoskeletons may be appropriate for individuals with paraplegia, but they overly constrain the volitional motion of individuals with remnant voluntary ability (representing a far larger population). Human-exoskeleton systems can be represented in the form of the Euler-Lagrange equations or, equivalently, the port-controlled Hamiltonian equations to design control laws…

Convex Neural Network-Based Cost Modifications for Learning Model Predictive Control

Katrine Seel, Arash Bahari Kordabad, Sébastien Gros et al. · 1 Jan 2022

Developing model predictive control (MPC) schemes can be challenging for systems where an accurate model is not available, or too costly to develop. With the increasing availability of data and tools to treat them, learning-based MPC has of late attracted wide attention. It has recently been shown that adapting not only the MPC model, but…

Human Trust in Robots: A Survey on Trust Models and Their Controls/Robotics Applications

Yue Wang, Fangjian Li, Huanfei Zheng et al. · 20 Dec 2023

Trust model is a topic that first gained interest in organizational studies and then human factors in automation. Thanks to recent advances in human-robot interaction (HRI) and human-autonomy teaming, human trust in robots has gained growing interest among researchers and practitioners. This article focuses on a survey of computational models of human-robot trust and their…

IEEE Open Journal of Control Systems template — frequently asked questions

How do I write a paper in the IEEE Open Journal of Control Systems format?
In DocuGuru you write your manuscript in a normal editor — no LaTeX setup required — and select the IEEE Open Journal of Control Systems template. When you export, DocuGuru compiles the paper into the official IEEE format and hands you a submission-ready PDF along with the editable LaTeX source.
What reference style does IEEE Open Journal of Control Systems use?
IEEE Open Journal of Control Systems uses Numbered (IEEE) references, shown as numbered [1], [2] markers in the text. DocuGuru formats every in-text citation and the reference list in this exact style automatically. A reference appears like this: [1] A. Smith, B. Jones, and C. Lee, "A representative article title," IEEE Open Journal of Control Systems, vol. 12, no. 3, pp. 45–58, 2023.
Do I need to know LaTeX to submit to IEEE Open Journal of Control Systems?
No. DocuGuru generates the ieeetj LaTeX class and compiles the PDF for you in the background, so you get a IEEE-ready IEEE Open Journal of Control Systems document without writing any LaTeX. If you do want it, the LaTeX source is included in the export.
Can I import an existing draft into the IEEE Open Journal of Control Systems template?
Yes. Paste or upload your current manuscript — Word, LaTeX, Markdown, or plain text — and DocuGuru reflows it into the IEEE Open Journal of Control Systems format with correct headings, figures, tables, and numbered citations.
What is IEEE Open Journal of Control Systems?
IEEE Open Journal of Control Systems, published by IEEE. It is a engineering and computer science journal, published by IEEE.
Can I export a submission-ready IEEE Open Journal of Control Systems PDF?
Yes — DocuGuru produces a PDF built with the official IEEE Open Journal of Control Systems template (the ieeetj class) that is ready to submit to IEEE, together with the matching LaTeX source files.
How much does the IEEE Open Journal of Control Systems template cost?
You can start writing in the IEEE Open Journal of Control Systems template for free. Exporting the final submission-ready IEEE Open Journal of Control Systems PDF and LaTeX source is part of DocuGuru's paid plans — see the app for current pricing.

Use the IEEE Open Journal of Control Systems template