ASME

Journal of Mechanisms and Robotics Template

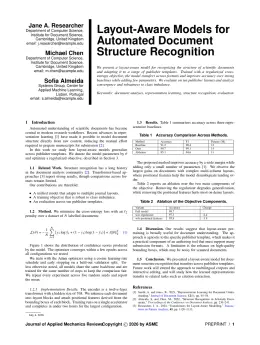
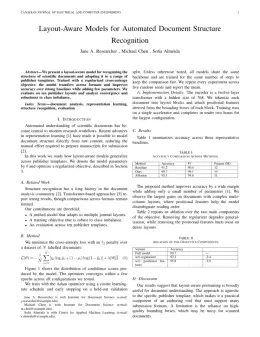
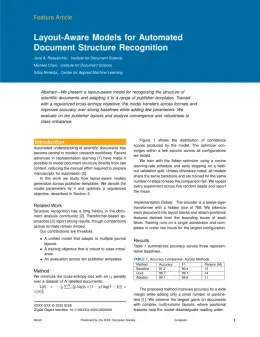
Write in a clean editor, then format for Journal of Mechanisms and Robotics in one click — DocuGuru applies the official ASME template with numbered references and exports a submission-ready PDF plus the editable LaTeX source. Free to start.

About the Journal of Mechanisms and Robotics format

Journal of Mechanisms and Robotics is a peer-reviewed journal published by ASME, covering Robotic Mechanisms and Dynamics, Soft Robotics and Applications, Robot Manipulation and Learning. Over its lifetime it has published 1,906 papers, which have received 33,716 citations.

PublisherASME
Reference styleNumbered (ASME)
Numbered — [1], [2] in the text
[1] Smith, A., Jones, B., and Lee, C., 2023, "A Representative Article Title," Journal of Mechanisms and Robotics, 12(3), pp. 45–58.

Formats any DOI in Journal of Mechanisms and Robotics style. No sign-up.

Publishes research inRobotic Mechanisms and Dynamics Soft Robotics and Applications Robot Manipulation and Learning Piezoelectric Actuators and Control Prosthetics and Rehabilitation Robotics
ISSN1942-4302
Citation impact (2-yr)2.28
h-index68
i10-index987
Top institutions publishing hereCentre National de la Recherche Scientifique
Journal websitemechanismsrobotics.asmedigitalcollection.asme.org
You getA submission-ready PDF and the editable LaTeX source — ready to submit.

Papers published in Journal of Mechanisms and Robotics per year

86
2014
129
2015
79
2016
113
2017
129
2018
153
2019
110
2020
161
2021
138
2022
154
2023
162
2024
118
2025

Citation impact of Journal of Mechanisms and Robotics by publication year

2.4K
2014
4K
2015
2.1K
2016
2.4K
2017
2.9K
2018
2.9K
2019
1.7K
2020
2K
2021
1.5K
2022
1.1K
2023
624
2024
133
2025

Citations each year’s papers have accumulated so far — the most recent years are still building up.

Most-cited papers in Journal of Mechanisms and Robotics

Analytic Formulation for Kinematics, Statics, and Shape Restoration of Multibackbone Continuum Robots Via Elliptic Integrals

Kai Xu, Nabil Simaan · 24 Nov 2009

This paper presents a novel and unified analytic formulation for kinematics, statics, and shape restoration of multiple-backbone continuum robots. These robots achieve actuation redundancy by independently pulling and pushing three backbones to carry out a bending motion of two-degrees-of-freedom (DoF). A solution framework based on constraints of geometric compatibility and static equilibrium is derived using…

A Pseudorigid-Body 3R Model for Determining Large Deflection of Cantilever Beams Subject to Tip Loads

Hai‐Jun Su · 7 Jan 2009

In this paper, a pseudorigid-body (PRB) 3R model, which consists of four rigid links joined by three revolute joints and three torsion springs, is proposed for approximating the deflection of a cantilever beam subject to a general tip load. The large deflection beam equations are solved through numerical integration. A comprehensive atlas of the tip…

Modeling Large Planar Deflections of Flexible Beams in Compliant Mechanisms Using Chained Beam-Constraint-Model1

Fulei Ma, Guimin Chen · 9 Jul 2015

Modeling large deflections has been one of the most fundamental problems in the research community of compliant mechanisms. Although many methods are available, there still exists a need for a method that is simple, accurate, and can be applied to a vast variety of large deflection problems. Based on the beam-constraint model (BCM), we propose…

A Comprehensive Elliptic Integral Solution to the Large Deflection Problems of Thin Beams in Compliant Mechanisms

Aimei Zhang, Guimin Chen · 26 Mar 2013

The elliptic integral solution is often considered to be the most accurate method for analyzing large deflections of thin beams in compliant mechanisms. In this paper, a comprehensive solution based on the elliptic integrals is proposed for solving large deflection problems. By explicitly incorporating the number of inflection points and the sign of the end-moment…

Design and Fabrication of a Soft Robotic Hand With Embedded Actuators and Sensors

Yu She, Chang Li, Jonathon Cleary et al. · 7 Jan 2015

This paper details the design and fabrication process of a fully integrated soft humanoid robotic hand with five finger that integrate an embedded shape memory alloy (SMA) actuator and a piezoelectric transducer (PZT) flexure sensor. Several challenges including precise control of the SMA actuator, improving power efficiency, and reducing actuation current and response time have…

Journal of Mechanisms and Robotics template — frequently asked questions

How do I write a paper in the Journal of Mechanisms and Robotics format?
In DocuGuru you write your manuscript in a normal editor — no LaTeX setup required — and select the Journal of Mechanisms and Robotics template. When you export, DocuGuru compiles the paper into the official ASME format and hands you a submission-ready PDF along with the editable LaTeX source.
What reference style does Journal of Mechanisms and Robotics use?
Journal of Mechanisms and Robotics uses Numbered (ASME) references, shown as numbered [1], [2] markers in the text. DocuGuru formats every in-text citation and the reference list in this exact style automatically. A reference appears like this: [1] Smith, A., Jones, B., and Lee, C., 2023, "A Representative Article Title," Journal of Mechanisms and Robotics, 12(3), pp. 45–58.
Do I need to know LaTeX to submit to Journal of Mechanisms and Robotics?
No. DocuGuru generates the asmejour LaTeX class and compiles the PDF for you in the background, so you get a ASME-ready Journal of Mechanisms and Robotics document without writing any LaTeX. If you do want it, the LaTeX source is included in the export.
Can I import an existing draft into the Journal of Mechanisms and Robotics template?
Yes. Paste or upload your current manuscript — Word, LaTeX, Markdown, or plain text — and DocuGuru reflows it into the Journal of Mechanisms and Robotics format with correct headings, figures, tables, and numbered citations.
What is Journal of Mechanisms and Robotics?
ASME journal. It is a engineering and computer science journal, published by ASME.
Can I export a submission-ready Journal of Mechanisms and Robotics PDF?
Yes — DocuGuru produces a PDF built with the official Journal of Mechanisms and Robotics template (the asmejour class) that is ready to submit to ASME, together with the matching LaTeX source files.
How much does the Journal of Mechanisms and Robotics template cost?
You can start writing in the Journal of Mechanisms and Robotics template for free. Exporting the final submission-ready Journal of Mechanisms and Robotics PDF and LaTeX source is part of DocuGuru's paid plans — see the app for current pricing.

Use the Journal of Mechanisms and Robotics template