ASME

Journal of Dynamic Systems, Measurement, and Control Template

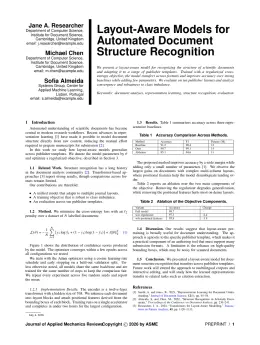
Write in a clean editor, then format for Journal of Dynamic Systems, Measurement, and Control in one click — DocuGuru applies the official ASME template with numbered references and exports a submission-ready PDF plus the editable LaTeX source. Free to start.

About the Journal of Dynamic Systems, Measurement, and Control format

Journal of Dynamic Systems, Measurement, and Control is a peer-reviewed journal published by ASME, covering Hydraulic and Pneumatic Systems, Advanced Control Systems Optimization, Adaptive Control of Nonlinear Systems. Over its lifetime it has published 5,867 papers, which have received 184,641 citations.

PublisherASME
Reference styleNumbered (ASME)
Numbered — [1], [2] in the text
[1] Smith, A., Jones, B., and Lee, C., 2023, "A Representative Article Title," Journal of Dynamic Systems, Measurement, and Control, 12(3), pp. 45–58.

Formats any DOI in Journal of Dynamic Systems, Measurement, and Control style. No sign-up.

Publishes research inHydraulic and Pneumatic Systems Advanced Control Systems Optimization Adaptive Control of Nonlinear Systems Dynamics and Control of Mechanical Systems Iterative Learning Control Systems
ISSN0022-0434
Citation impact (2-yr)0.85
h-index156
i10-index2,887
Top institutions publishing hereUniversity of California, Berkeley
You getA submission-ready PDF and the editable LaTeX source — ready to submit.

Papers published in Journal of Dynamic Systems, Measurement, and Control per year

209
2014
136
2015
198
2016
206
2017
190
2018
159
2019
124
2020
115
2021
85
2022
73
2023
81
2024
106
2025

Citation impact of Journal of Dynamic Systems, Measurement, and Control by publication year

3.6K
2014
2.2K
2015
2.7K
2016
2.4K
2017
2.2K
2018
1.9K
2019
1.1K
2020
946
2021
597
2022
255
2023
141
2024
48
2025

Citations each year’s papers have accumulated so far — the most recent years are still building up.

Most-cited papers in Journal of Dynamic Systems, Measurement, and Control

Modern Control Engineering

K. Ogata, J. W. Brewer · 1 Mar 1971

From the Publisher: This comprehensive treatment of the analysis and design of continuous-time control systems provides a gradual development of control theory—and shows how to solve all computational problems with MATLAB. It avoids highly mathematical arguments, and features an abundance of examples and worked problems throughout the book. Chapter topics include the Laplace transform; mathematical modeling…

6,354 citations Cite SaveGo to paper →
Impedance Control: An Approach to Manipulation: Part I—Theory

Neville Hogan · 1 Mar 1985

Manipulation fundamentally requires the manipulator to be mechanically coupled to the object being manipulated; the manipulator may not be treated as an isolated system. This three-part paper presents an approach to the control of dynamic interaction between a manipulator and its environment. In Part I this approach is developed by considering the mechanics of interaction…

3,622 citations Cite SaveGo to paper →
Feedback Systems: Input-Output Properties

C. Desoer, M. Vidyasagar, A.N. Willson · 1 Dec 1975

Preface to the Classics edition Preface Acknowledgments Note to the reader List of symbols 1. Memoryless nonlinearities 2. Norms 3. General theorems 4. Linear systems 5. Applications of the small gain theorem 6. Passivity Appendix A. Integrals and series Appendix B. Fourier transforms Appendix C. Convolution Appendix D. Algebras Appendix E. Bellman-Gronwall Lemma References Index.

3,252 citations Cite SaveGo to paper →
Hybrid Position/Force Control of Manipulators

Marc H. Raibert, John Craig · 1 Jun 1981

A new conceptually simple approach to controlling compliant motions of a robot manipulator is presented. The “hybrid” technique described combines force and torque information with positional data to satisfy simultaneous position and force trajectory constraints specified in a convenient task related coordinate system. Analysis, simulation, and experiments are used to evaluate the controller’s ability to…

2,984 citations Cite SaveGo to paper →

Journal of Dynamic Systems, Measurement, and Control template — frequently asked questions

How do I write a paper in the Journal of Dynamic Systems, Measurement, and Control format?
In DocuGuru you write your manuscript in a normal editor — no LaTeX setup required — and select the Journal of Dynamic Systems, Measurement, and Control template. When you export, DocuGuru compiles the paper into the official ASME format and hands you a submission-ready PDF along with the editable LaTeX source.
What reference style does Journal of Dynamic Systems, Measurement, and Control use?
Journal of Dynamic Systems, Measurement, and Control uses Numbered (ASME) references, shown as numbered [1], [2] markers in the text. DocuGuru formats every in-text citation and the reference list in this exact style automatically. A reference appears like this: [1] Smith, A., Jones, B., and Lee, C., 2023, "A Representative Article Title," Journal of Dynamic Systems, Measurement, and Control, 12(3), pp. 45–58.
Do I need to know LaTeX to submit to Journal of Dynamic Systems, Measurement, and Control?
No. DocuGuru generates the asmejour LaTeX class and compiles the PDF for you in the background, so you get a ASME-ready Journal of Dynamic Systems, Measurement, and Control document without writing any LaTeX. If you do want it, the LaTeX source is included in the export.
Can I import an existing draft into the Journal of Dynamic Systems, Measurement, and Control template?
Yes. Paste or upload your current manuscript — Word, LaTeX, Markdown, or plain text — and DocuGuru reflows it into the Journal of Dynamic Systems, Measurement, and Control format with correct headings, figures, tables, and numbered citations.
What is Journal of Dynamic Systems, Measurement, and Control?
ASME journal. It is a engineering and computer science journal, published by ASME.
Can I export a submission-ready Journal of Dynamic Systems, Measurement, and Control PDF?
Yes — DocuGuru produces a PDF built with the official Journal of Dynamic Systems, Measurement, and Control template (the asmejour class) that is ready to submit to ASME, together with the matching LaTeX source files.
How much does the Journal of Dynamic Systems, Measurement, and Control template cost?
You can start writing in the Journal of Dynamic Systems, Measurement, and Control template for free. Exporting the final submission-ready Journal of Dynamic Systems, Measurement, and Control PDF and LaTeX source is part of DocuGuru's paid plans — see the app for current pricing.

Use the Journal of Dynamic Systems, Measurement, and Control template